← Studies · prototype · 2026

§ 3.06

Robotics Interaction — VLM + hand tracking on UF850

Two ways for a six-axis robot to respond: interpret the room through a vision-language model, or mirror a person through hand tracking. One webcam turns perception into live, expressive motion.

Methods
Human–robot interaction · VLM · MediaPipe · Real-time control · Safety
Robotics Interaction — VLM + hand tracking on UF850 cover
01 · notes

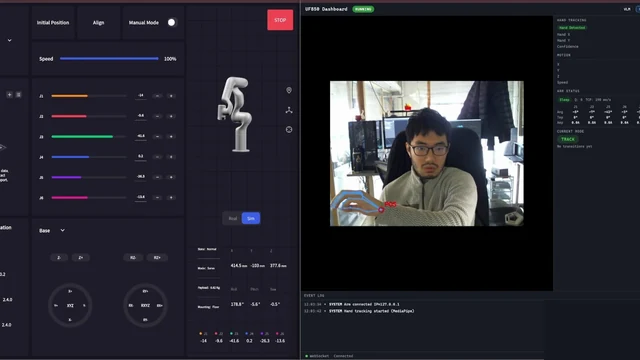
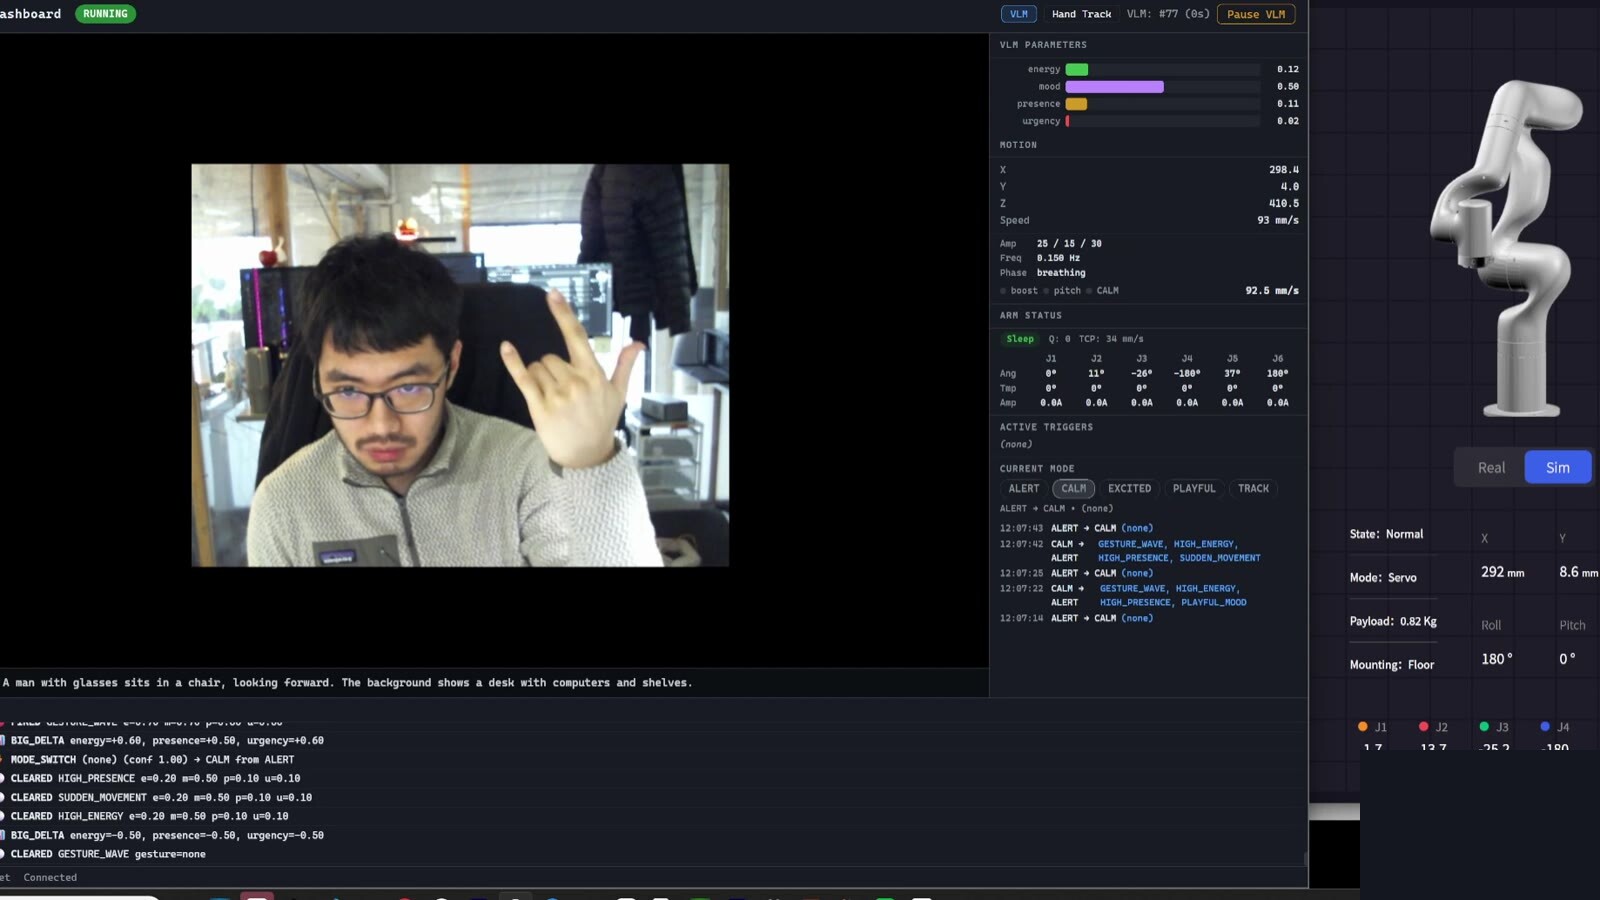
In VLM mode, Gemini reads energy, mood, presence, urgency, and gestures, then selects a motion behavior. In tracking mode, MediaPipe maps a person's hand directly to the arm's position and pitch.

The core ideas are semantic perception, embodied interaction, organic motion, and safe real-time control. Both modes share the same Cartesian motion pipeline, filtering, workspace limits, and recovery logic.
interaction modes

Two control modes running through the same motion and safety system.

MediaPipe hand tracking — live hand landmarks drive the robot's position and pitch
Gemini VLM interaction — scene context and gestures become higher-level motion behaviors
02 · process · 1 image
VLM interaction mode — scene parameters, gesture state, arm telemetry, and the live camera feed in one debugging dashboard