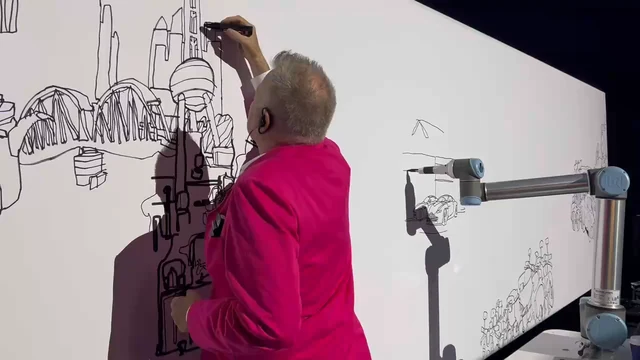
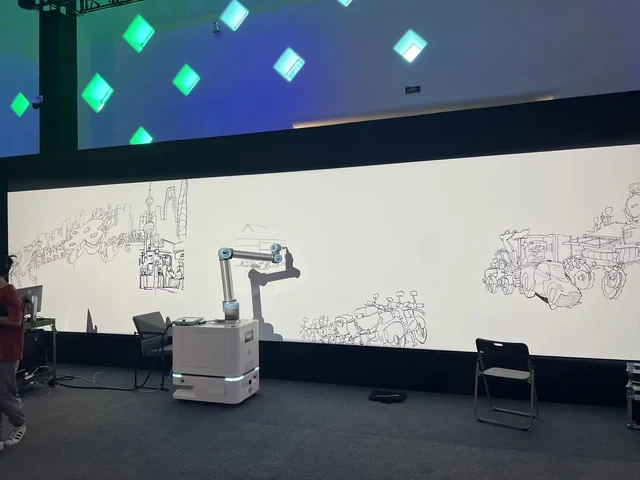
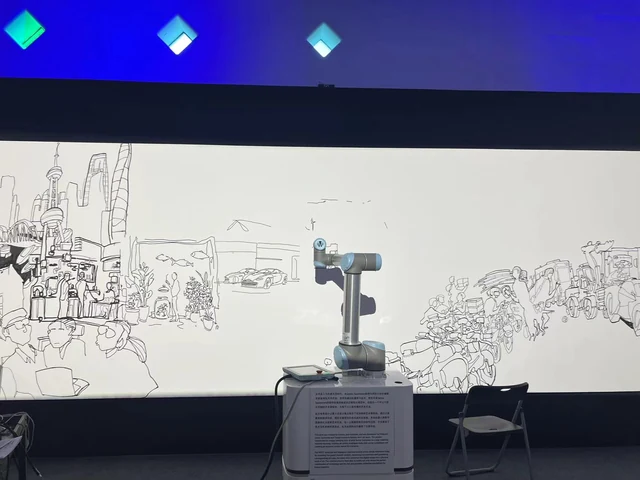
AI Artistic Painting — Human–Robot Collaboration was a live generative drawing performance presented at the opening ceremony of the 2024 World Design Cities Conference in Shanghai. Keywords extracted from conference speeches became images in architect and artist Jarmo Suominen's visual language, then ordered vector paths for a robotic arm. On stage, Suominen and the robot drew simultaneously across a monumental wall.
The job was to turn an image model into a drawing system. A prompt had to move through generation, geometry processing, and robot control without asking the operator to rebuild the file by hand.
PROMPT──→COMFYUI──→LoRA IMAGE──→HOUDINI──→SVG──→GRASSHOPPER──→ROBOT ARM
[01 / SOURCE]
Artist drawings
A few dozen abstract line drawings from murals and related work were collected and cleaned by hand before training.
[02 / LEARN]
Stable Diffusion + LoRA
Captioning and training were balanced to retain the artist’s visual language without memorizing the small dataset. The model needed enough range to draw subjects beyond the examples.
[03 / VECTOR]
Trace + Houdini
Generated images were traced into vectors. Houdini reduced broken fragments, retained useful detail, and arranged the strokes into a practical drawing order.
[04 / AUTOMATE]
ComfyUI + headless Houdini
The ComfyUI graph was exported as JSON. A .bat script launched Houdini without its interface, processed the paths, and wrote the final SVG.
[05 / DRAW]
Grasshopper + robot arm
Grasshopper received the ordered SVG paths and passed them into the robotic drawing system for physical execution.
USER EXPERIENCEprompt in→robot-ready SVG out
// 02 · my contribution
I built the image-to-drawing workflow from training data to robot-ready geometry. This included preparing the artist's drawings, training a Stable Diffusion LoRA, building the ComfyUI graph, tracing generated images, and using Houdini to simplify and order the vector paths.
I then automated the pipeline: ComfyUI supplied the generation graph as JSON, a .bat script ran Houdini headlessly, and the system exported an SVG for the Grasshopper robot-control setup. I remotely tested the venue installation through its final overnight setup.